Makerbuying Logo小钉锤 · 全球服务
← 产品
SNAM100Industrial robot model 6-degree-of-freedom robot arm teaching tool for arduino uno
SNAM Robot Arm

SNAM100Industrial robot model 6-degree-of-freedom robot arm teaching tool for arduino uno

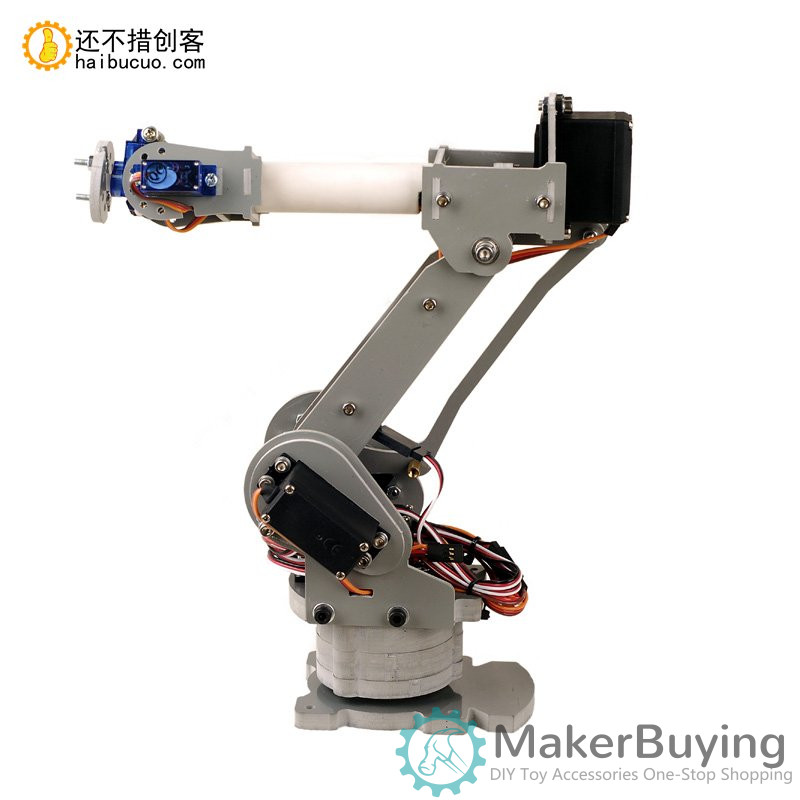
What can a six axis robotic arm model do? The robotic arm model is a structural proportion

官网原始名称

SNAM100Industrial robot model 6-degree-of-freedom robot arm teaching tool for arduino uno

来源:Makerbuying 官网 · 采集日期:2026-11-04。原始名称中的编号与版本写法保留来源信息,具体参数、套装内容和兼容性请以官网确认结果为准。

查看官网产品 ↗

本页用于产品展示,不提供站内下单,不显示未经确认的实时价格或库存。

Original product documentation

Archived from the official source. Refer to the source product page for the latest specifications and configuration.

What can a six axis robotic arm model do? The robotic arm model is a structural proportion model of ABB industrial robots, which can actually control the movement according to the CNC concept. It is suitable for teaching experiments, focuses on motion demonstration, and does not have actual load-bearing work ability. What does a six axis robotic arm look like when it moves? Video address: (Copy address to open) http://v.youku.com/v_show/id_XODMyMzYzOTg4.html What material is the robotic arm made of? The board of the robotic arm model is made of PVC engineering plastic and processed through CNC machining. The power bottleneck of the robotic arm lies in the torque of the servo. The board of the robotic arm has not yet deformed, and the servo is weak. Another advantage of PVC engineering plastic is that the material’s ductility is very suitable for embedding bearings. Using bearings to connect increases the accuracy of the structure. All joints of the robotic arm are connected with high-quality bearings. What are the six degrees of freedom and angle range of each axis for a six axis robotic arm? Six degrees of freedom of a robotic arm: a: Waist 0-180 degrees b: The large and small arms interact with each other, and the range of rotation angle is a variable c: The forearm and forearm interact with each other, and the range of rotation angle is a variable d: Forearm rotation 0-180 degrees e: Wrist 0-180 degrees f: Claw 0-180 degrees (0-180 degrees is the theoretical value, the actual angle is between 5-175 degrees)

技术文档

装配前检查清单 →

技术交流 →